A robot spider is surrounded by several small robots, showcasing a futuristic assembly of robotic technology.

GPU-Accelerated Real-Time Control and Simulation of Magnetically Actuated Microbot Swarms for Targeted Drug Delivery.

This article examines how GPUs enable sub‑millisecond control of magnetically actuated microrobot swarms by accelerating many‑body physics, swarm simulation, and reinforcement‑learning‑based navigation.
2026-05-24 · 13 min · Theophilus Eriata
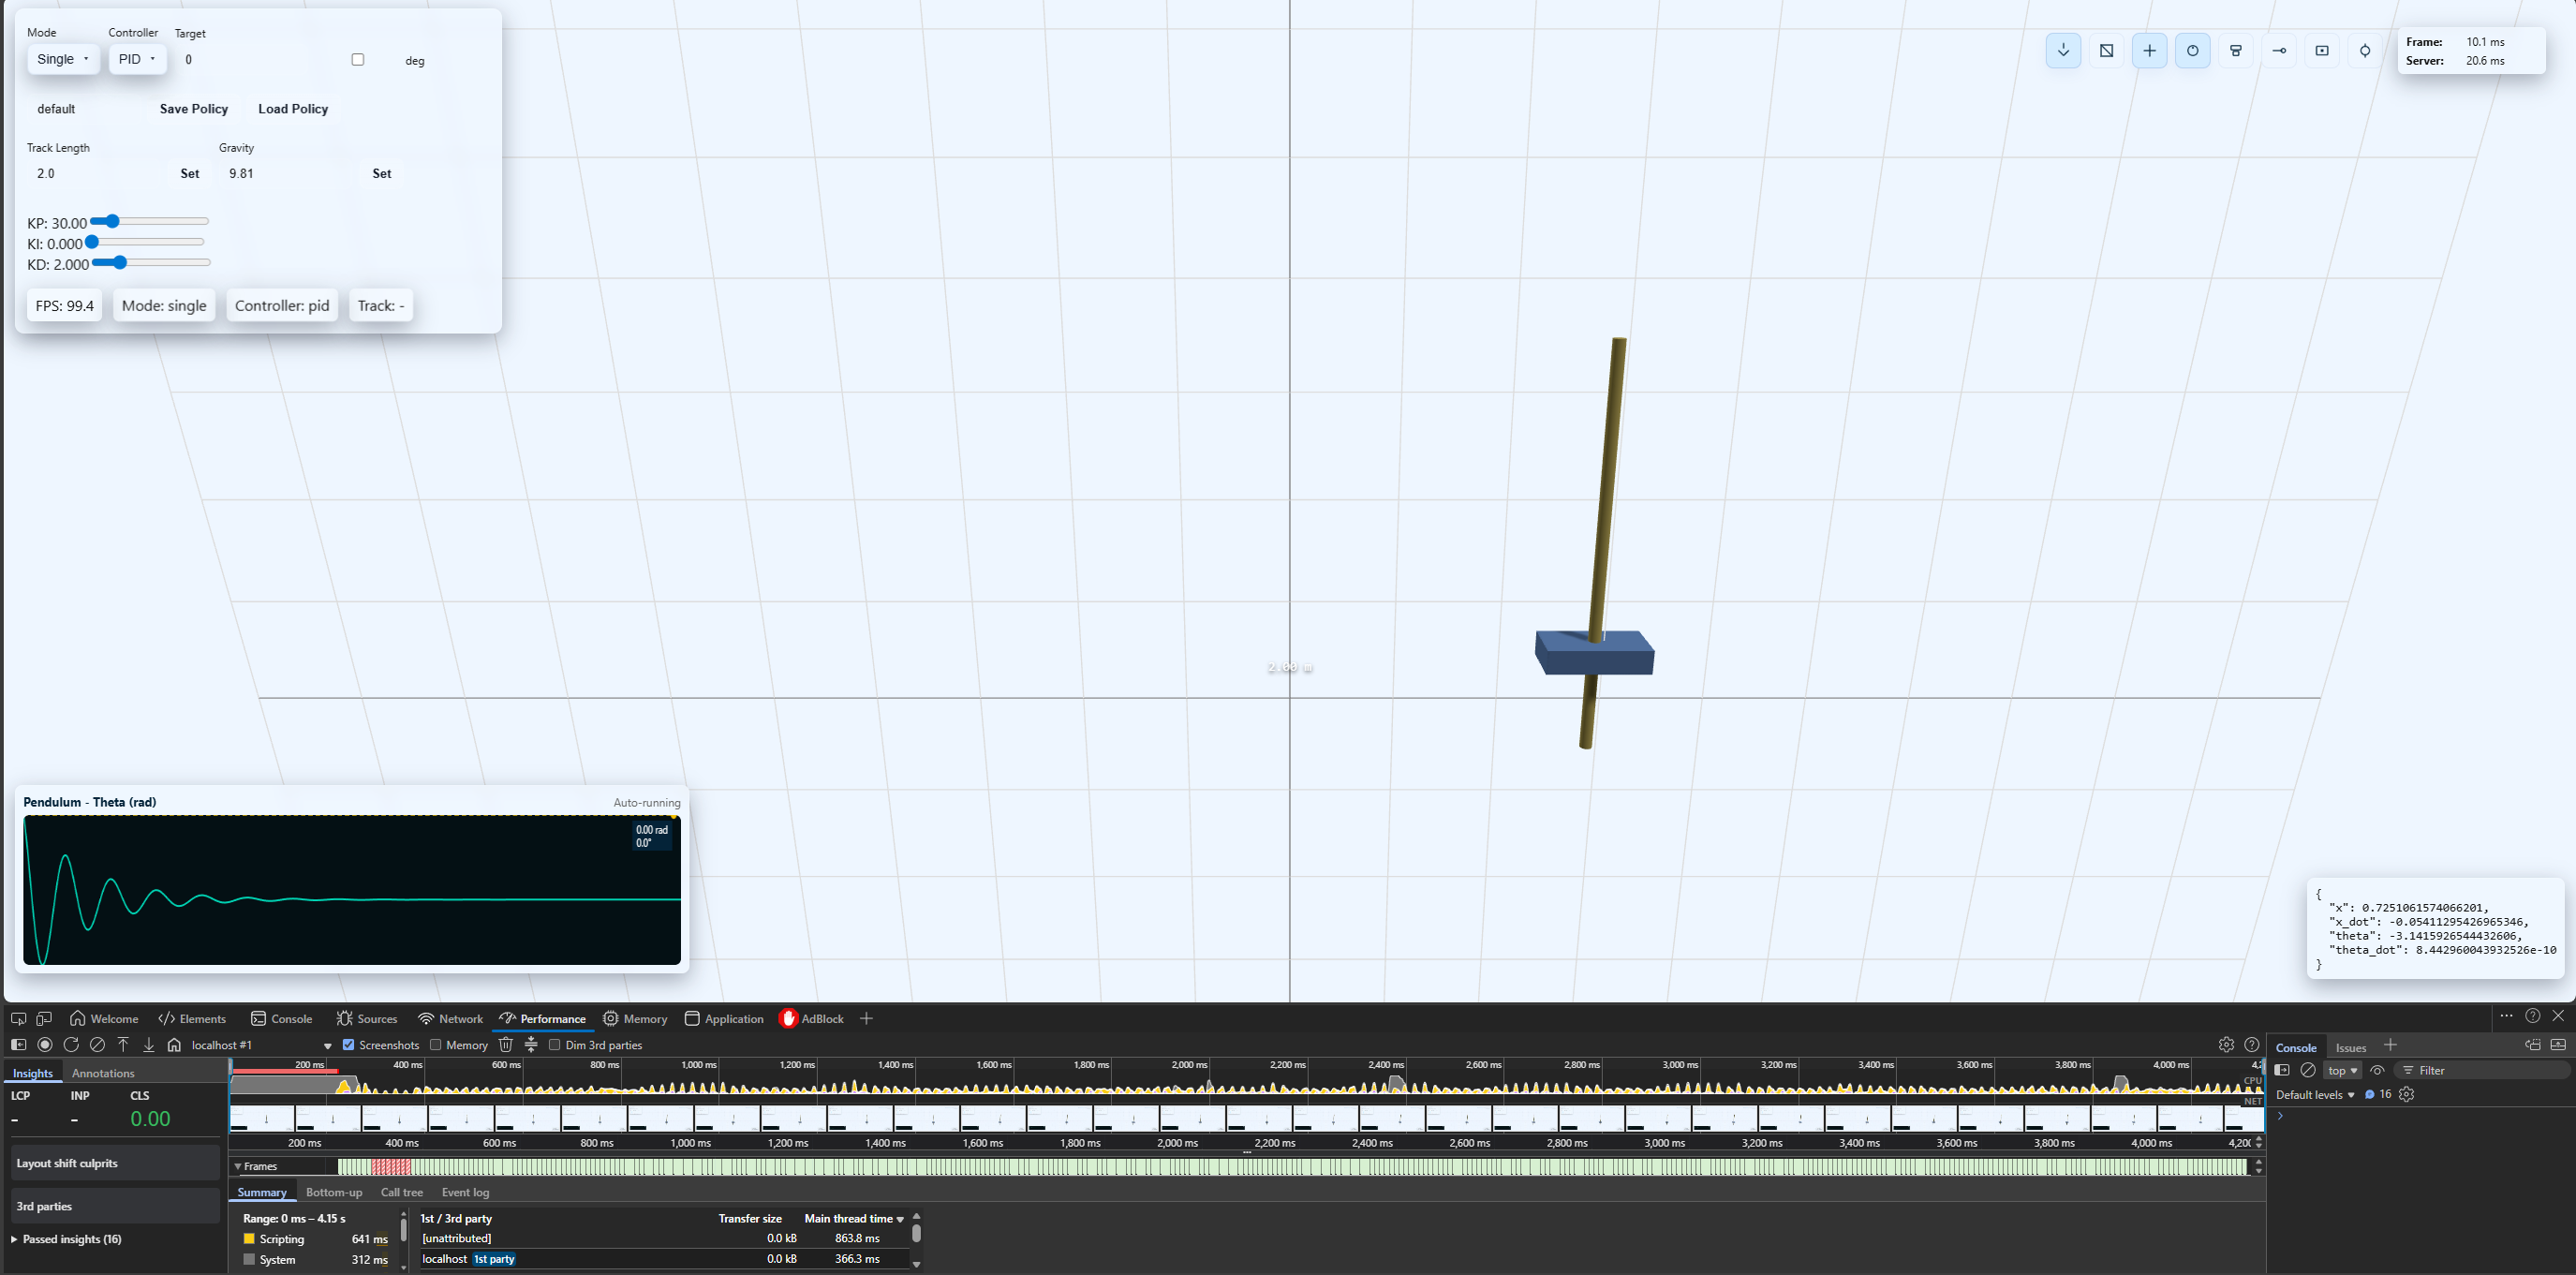
Balancing a single pendulum.

Neural Networks and Reinforcement Learning: Practical Workshop Materials

Workshop materials covering PD control baselines, MLP policy imitation, double pendulum stabilization, gait generation, reward shaping, and lightweight environment wrappers.

2025-11-19 · 2 min · Theophilus Eriata
A futuristic robot hummingbird operating with precision in a controlled environment.

Designing for Determinism in Robotics Frameworks

This article examines the importance of deterministic execution in robotics frameworks, where predictable timing and behavior are essential for safety, reliability, and performance. It discusses scheduling models, hard and soft real-time constraints, and the role of real-time operating systems in ensuring consistent control loop execution. Practical design strategies and trade-offs are explored to help engineers build robust, time-predictable robotic systems.

2025-09-11 · 17 min · Theophilus Eriata
FIRST Tech Challenge Logo

Empowering an All-Girls FTC Team: Math, Code & Robotics in Power Play

An in-depth look at mentoring an all-girls FIRST Tech Challenge team, covering linear algebra, control theory, vision pipelines, software design, and collaborative workshops.

2023-07-23 · 23 min · Theophilus Eriata